



Mini Plotter CNC 2D com Drive de DVD Reciclado e Shield L293D
Componentes e Materiais
- 1x Arduino UNO (cérebro da máquina)
- 1x Shield L293D Motor Driver (controla steppers dos eixos)
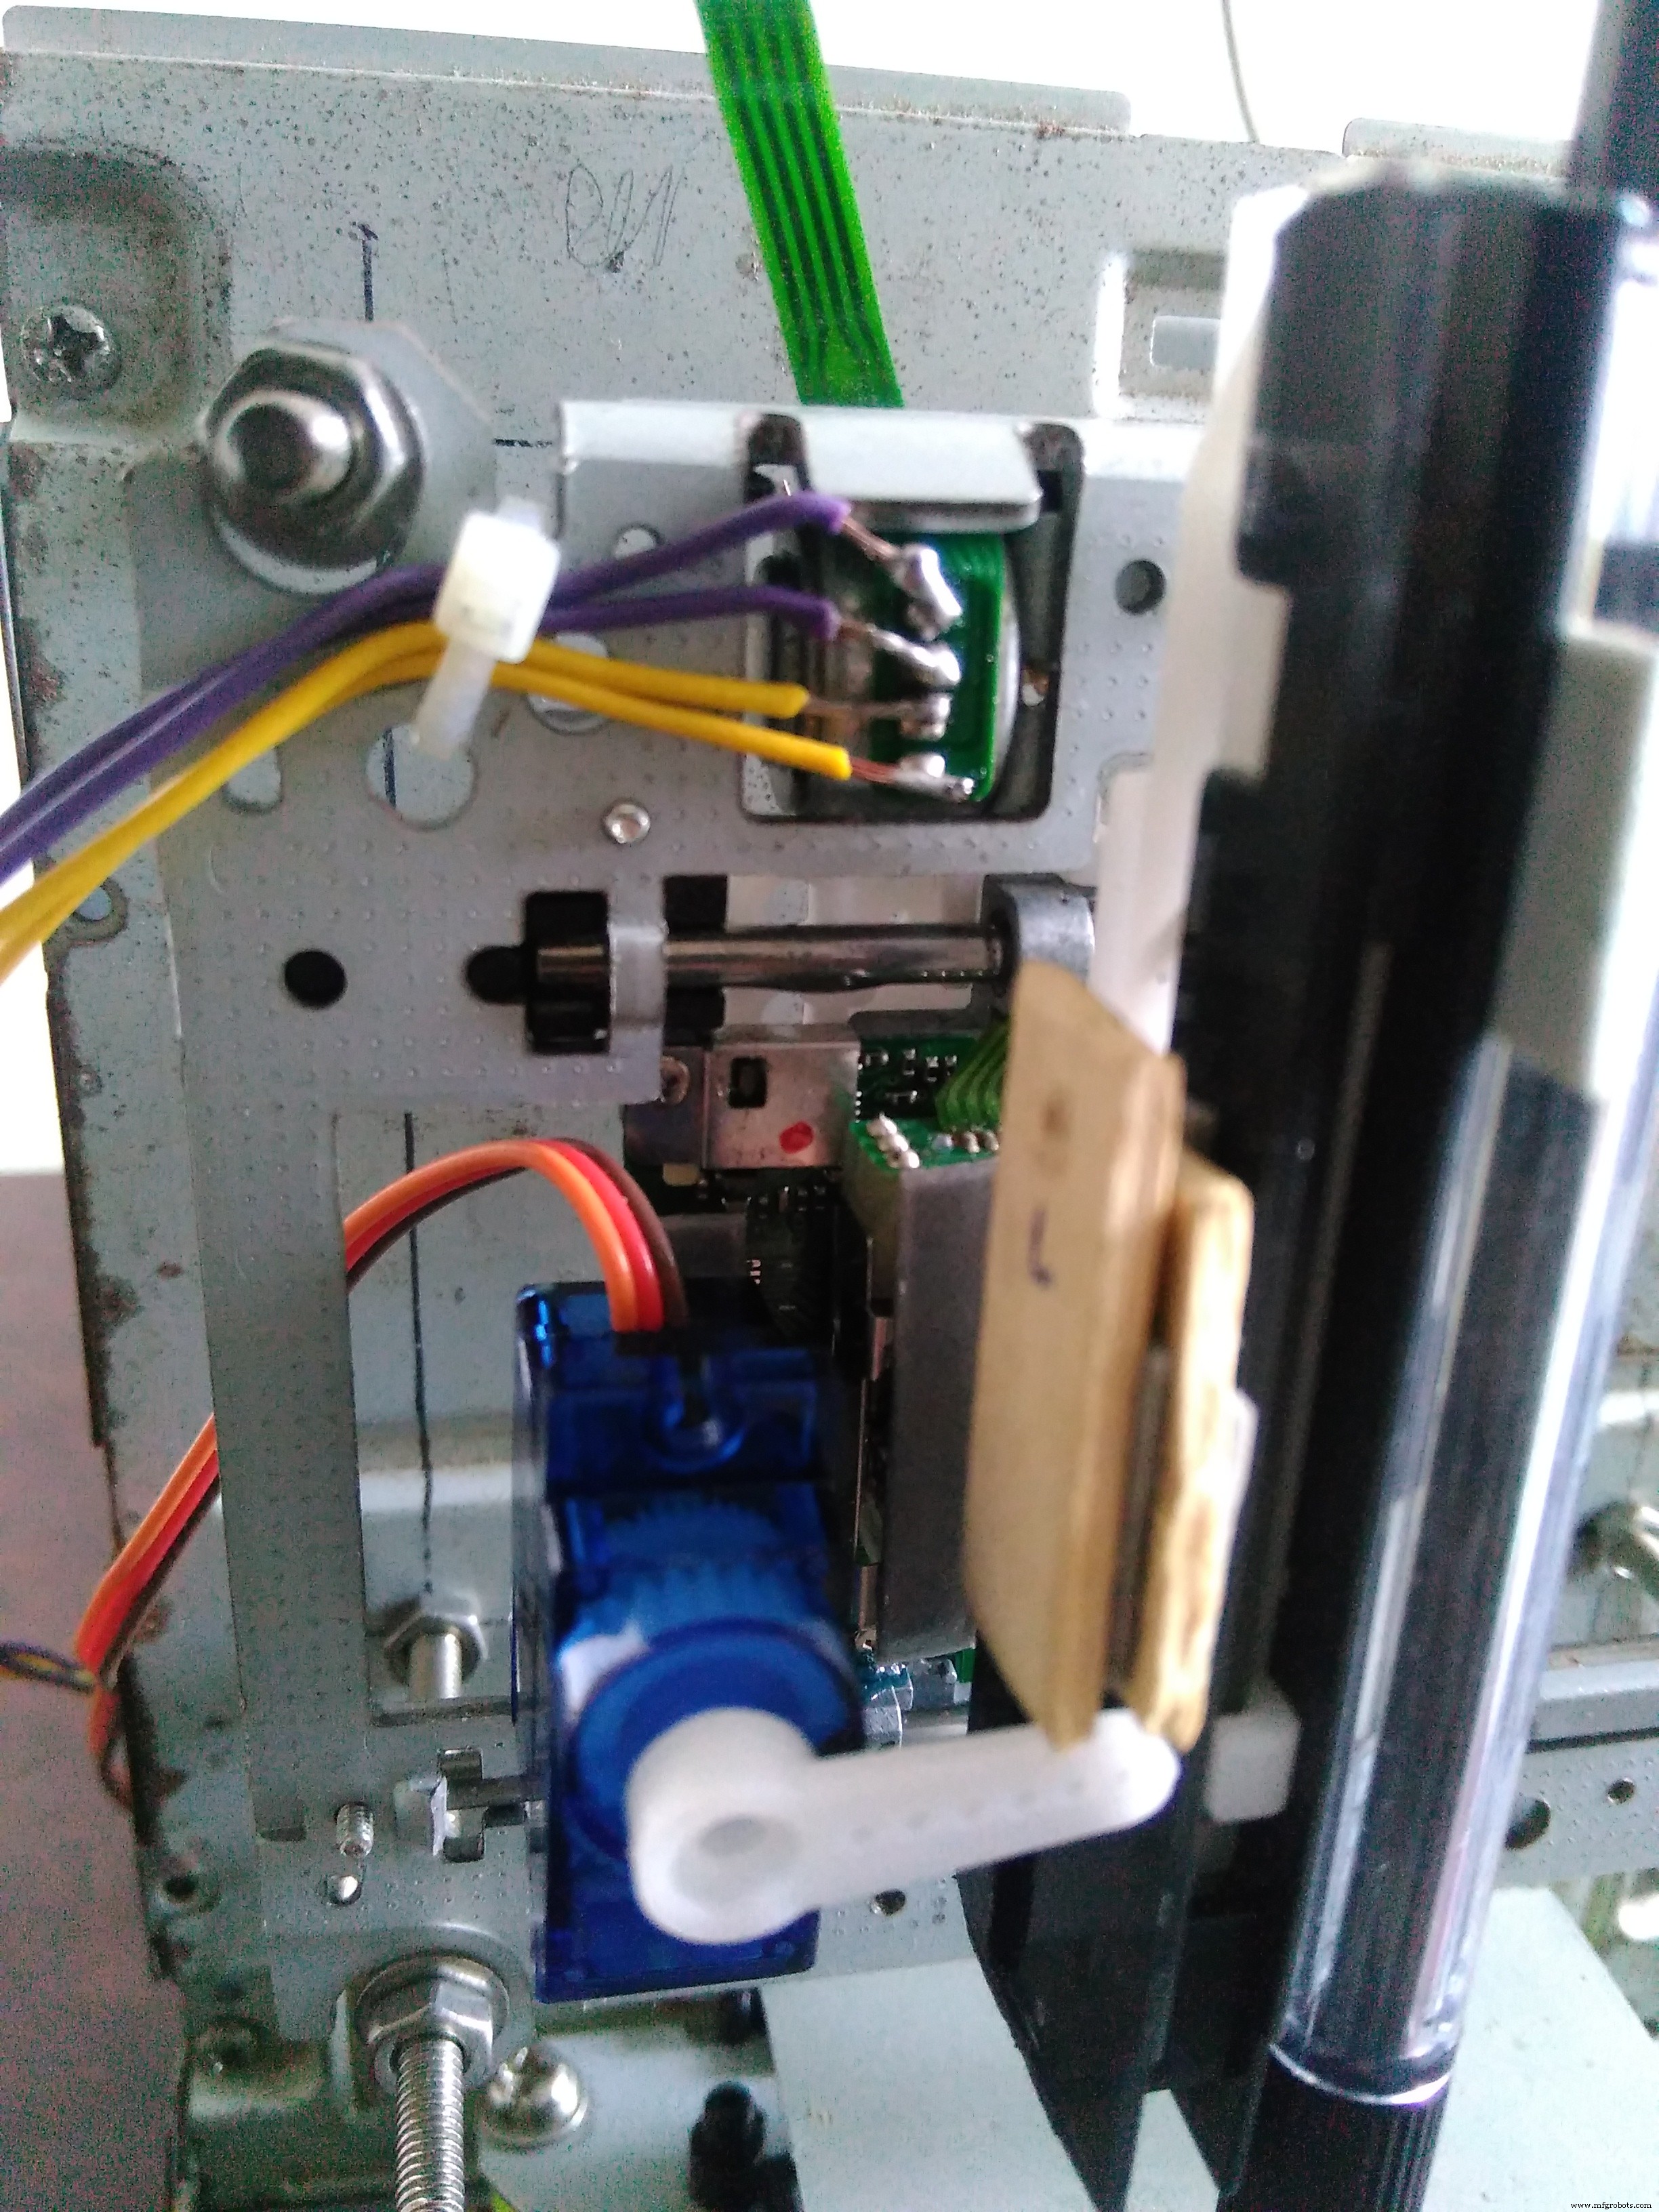
- 1x Servo Tower Pro 9g (movimento Z: caneta UP/DOWN)
- 1x Drive de DVD sucateado (mecânica eixos X e Y)
- Jumpers (genéricos)
Aplicativos e Serviços Online
- Arduino IDE
- Processing IDE
- Inkscape (vetor → G-code)
Sobre o Projeto
Montagem dos Dois Drives de DVD
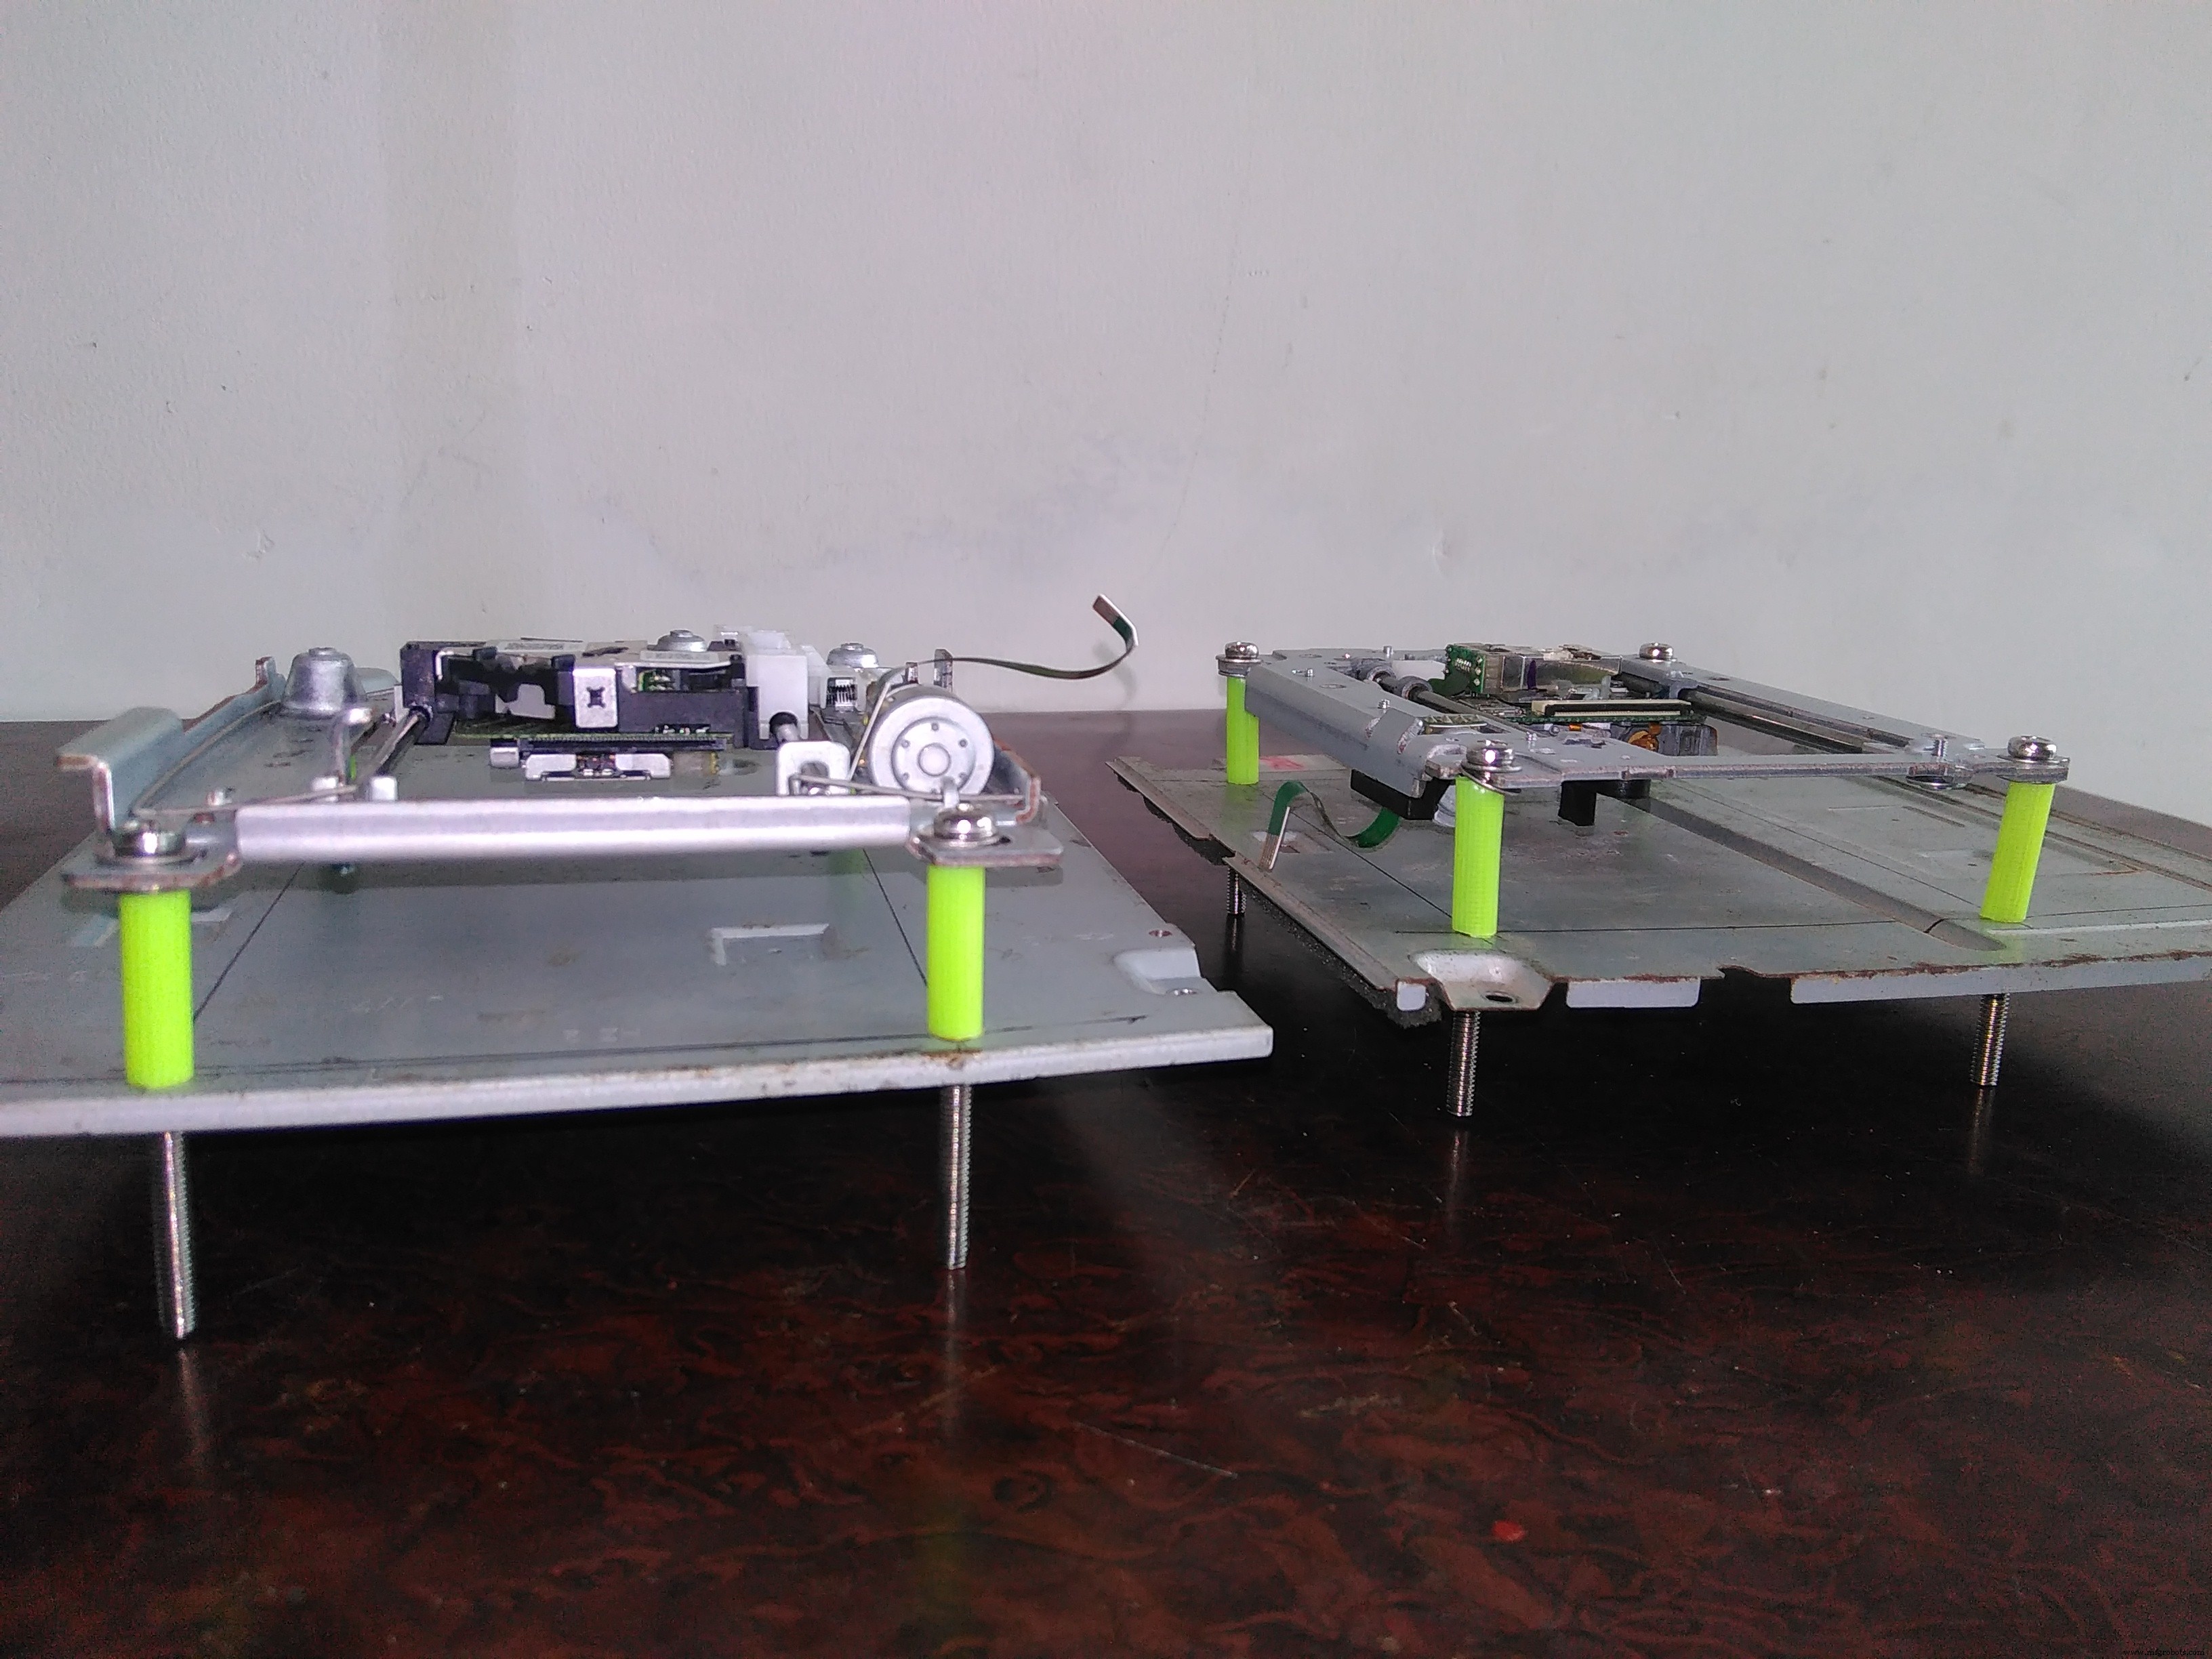
Organize dois drives de DVD sucateados conforme a imagem:
- Baixe Arduino IDE
- Baixe Processing IDE
- Abra Arduino IDE e carregue o código aqui.
- Abra Processing IDE e carregue o código aqui.
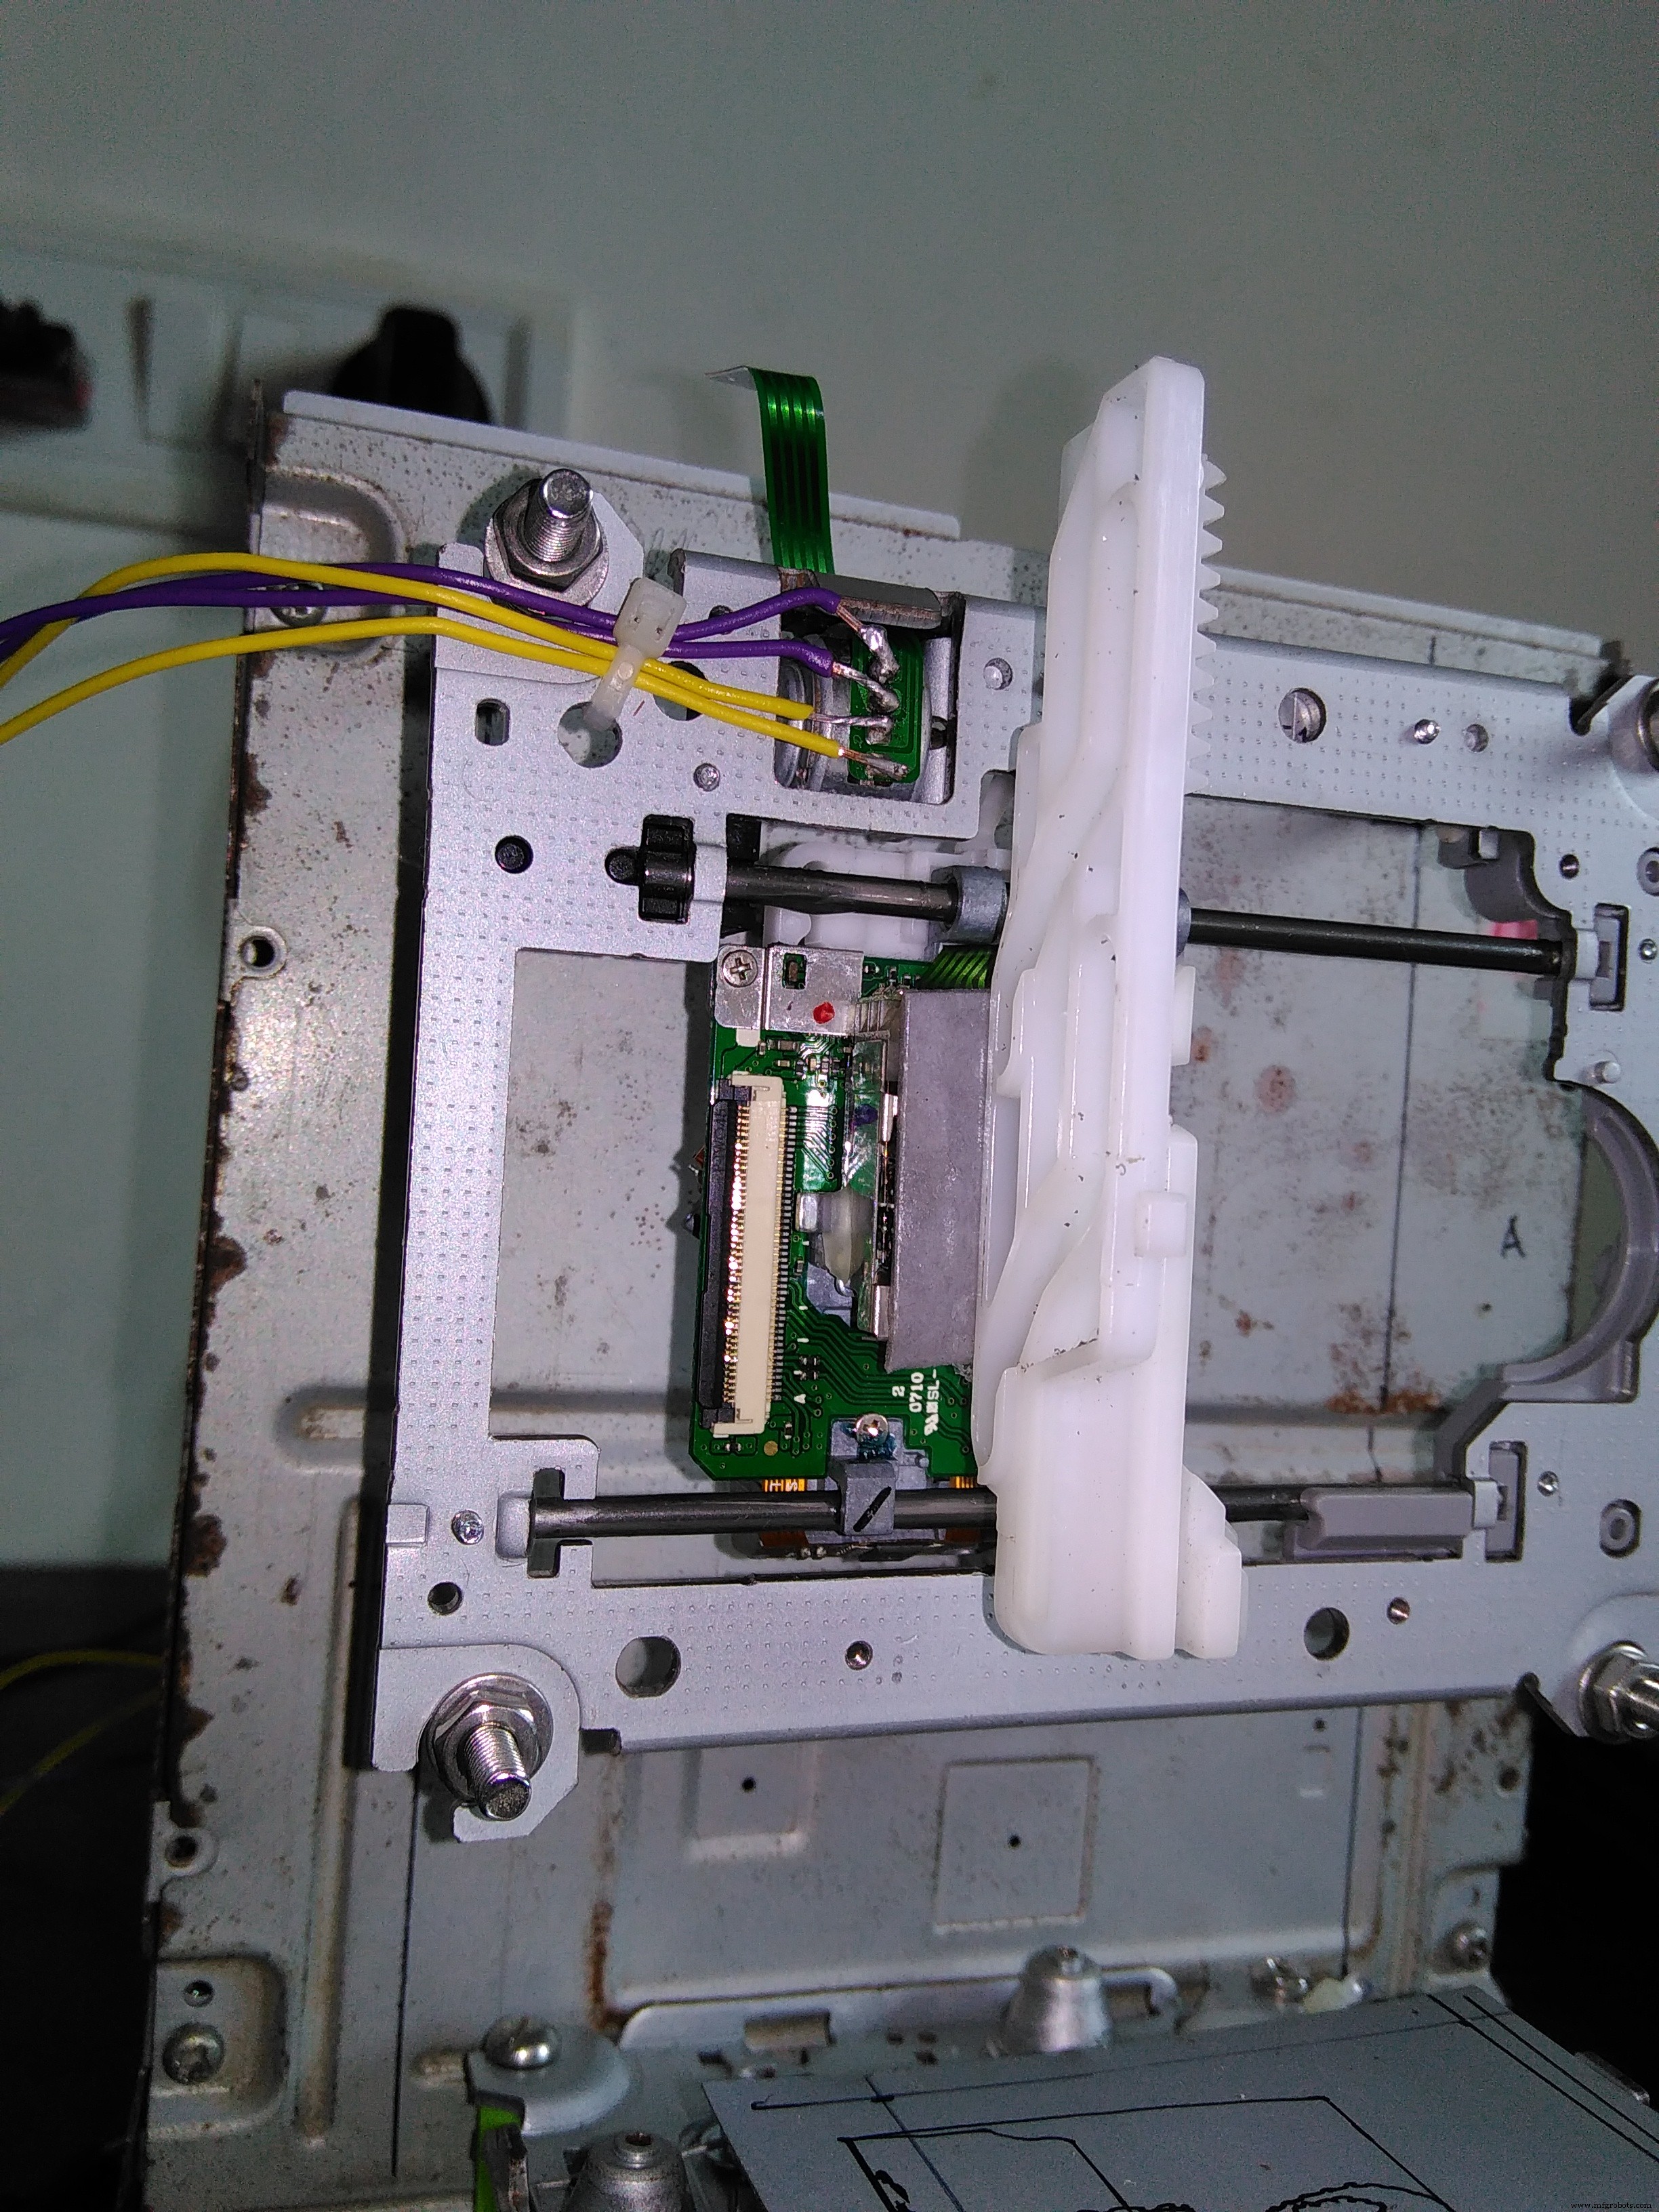
Abra o drive de DVD e remova a bandeja interna móvel. Esta bandeja tem mecanismo de stepper – será nossos eixos X e Y. Veja fotos anexas para montagem. Fure a carcaça vazia do DVD para fixar eixos X e Y com porcas/parafusos.
Posicione-os perpendiculares entre si.
G-code
Para gerar arquivos G-code compatíveis, use o Inkscape.
Inkscape é software vetorial profissional (Windows/Mac/Linux), gratuito e open-source. Usa SVG nativo. Importante: baixe versão 0.48.5. Instale add-on para exportar imagens para G-code (aqui com instruções).
Siga vídeo no YouTube para criar G-code.
- Carregue arquivo
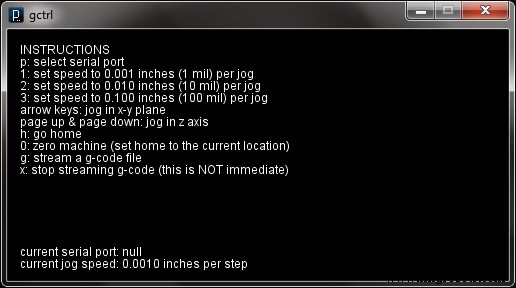
gctrlno Processing IDE e clique PLAY. - Pressione 'p' para selecionar porta serial.
- Opcional: defina velocidade jog com 1, 2 ou 3 no teclado.
- Pressione 'g' para carregar arquivo G-code.
- Máquina pronta para plotar ao dar Enter selecionando o arquivo.
Arquivos G-code prontos para testar:
Obrigado! Visite link para ilustração completa.
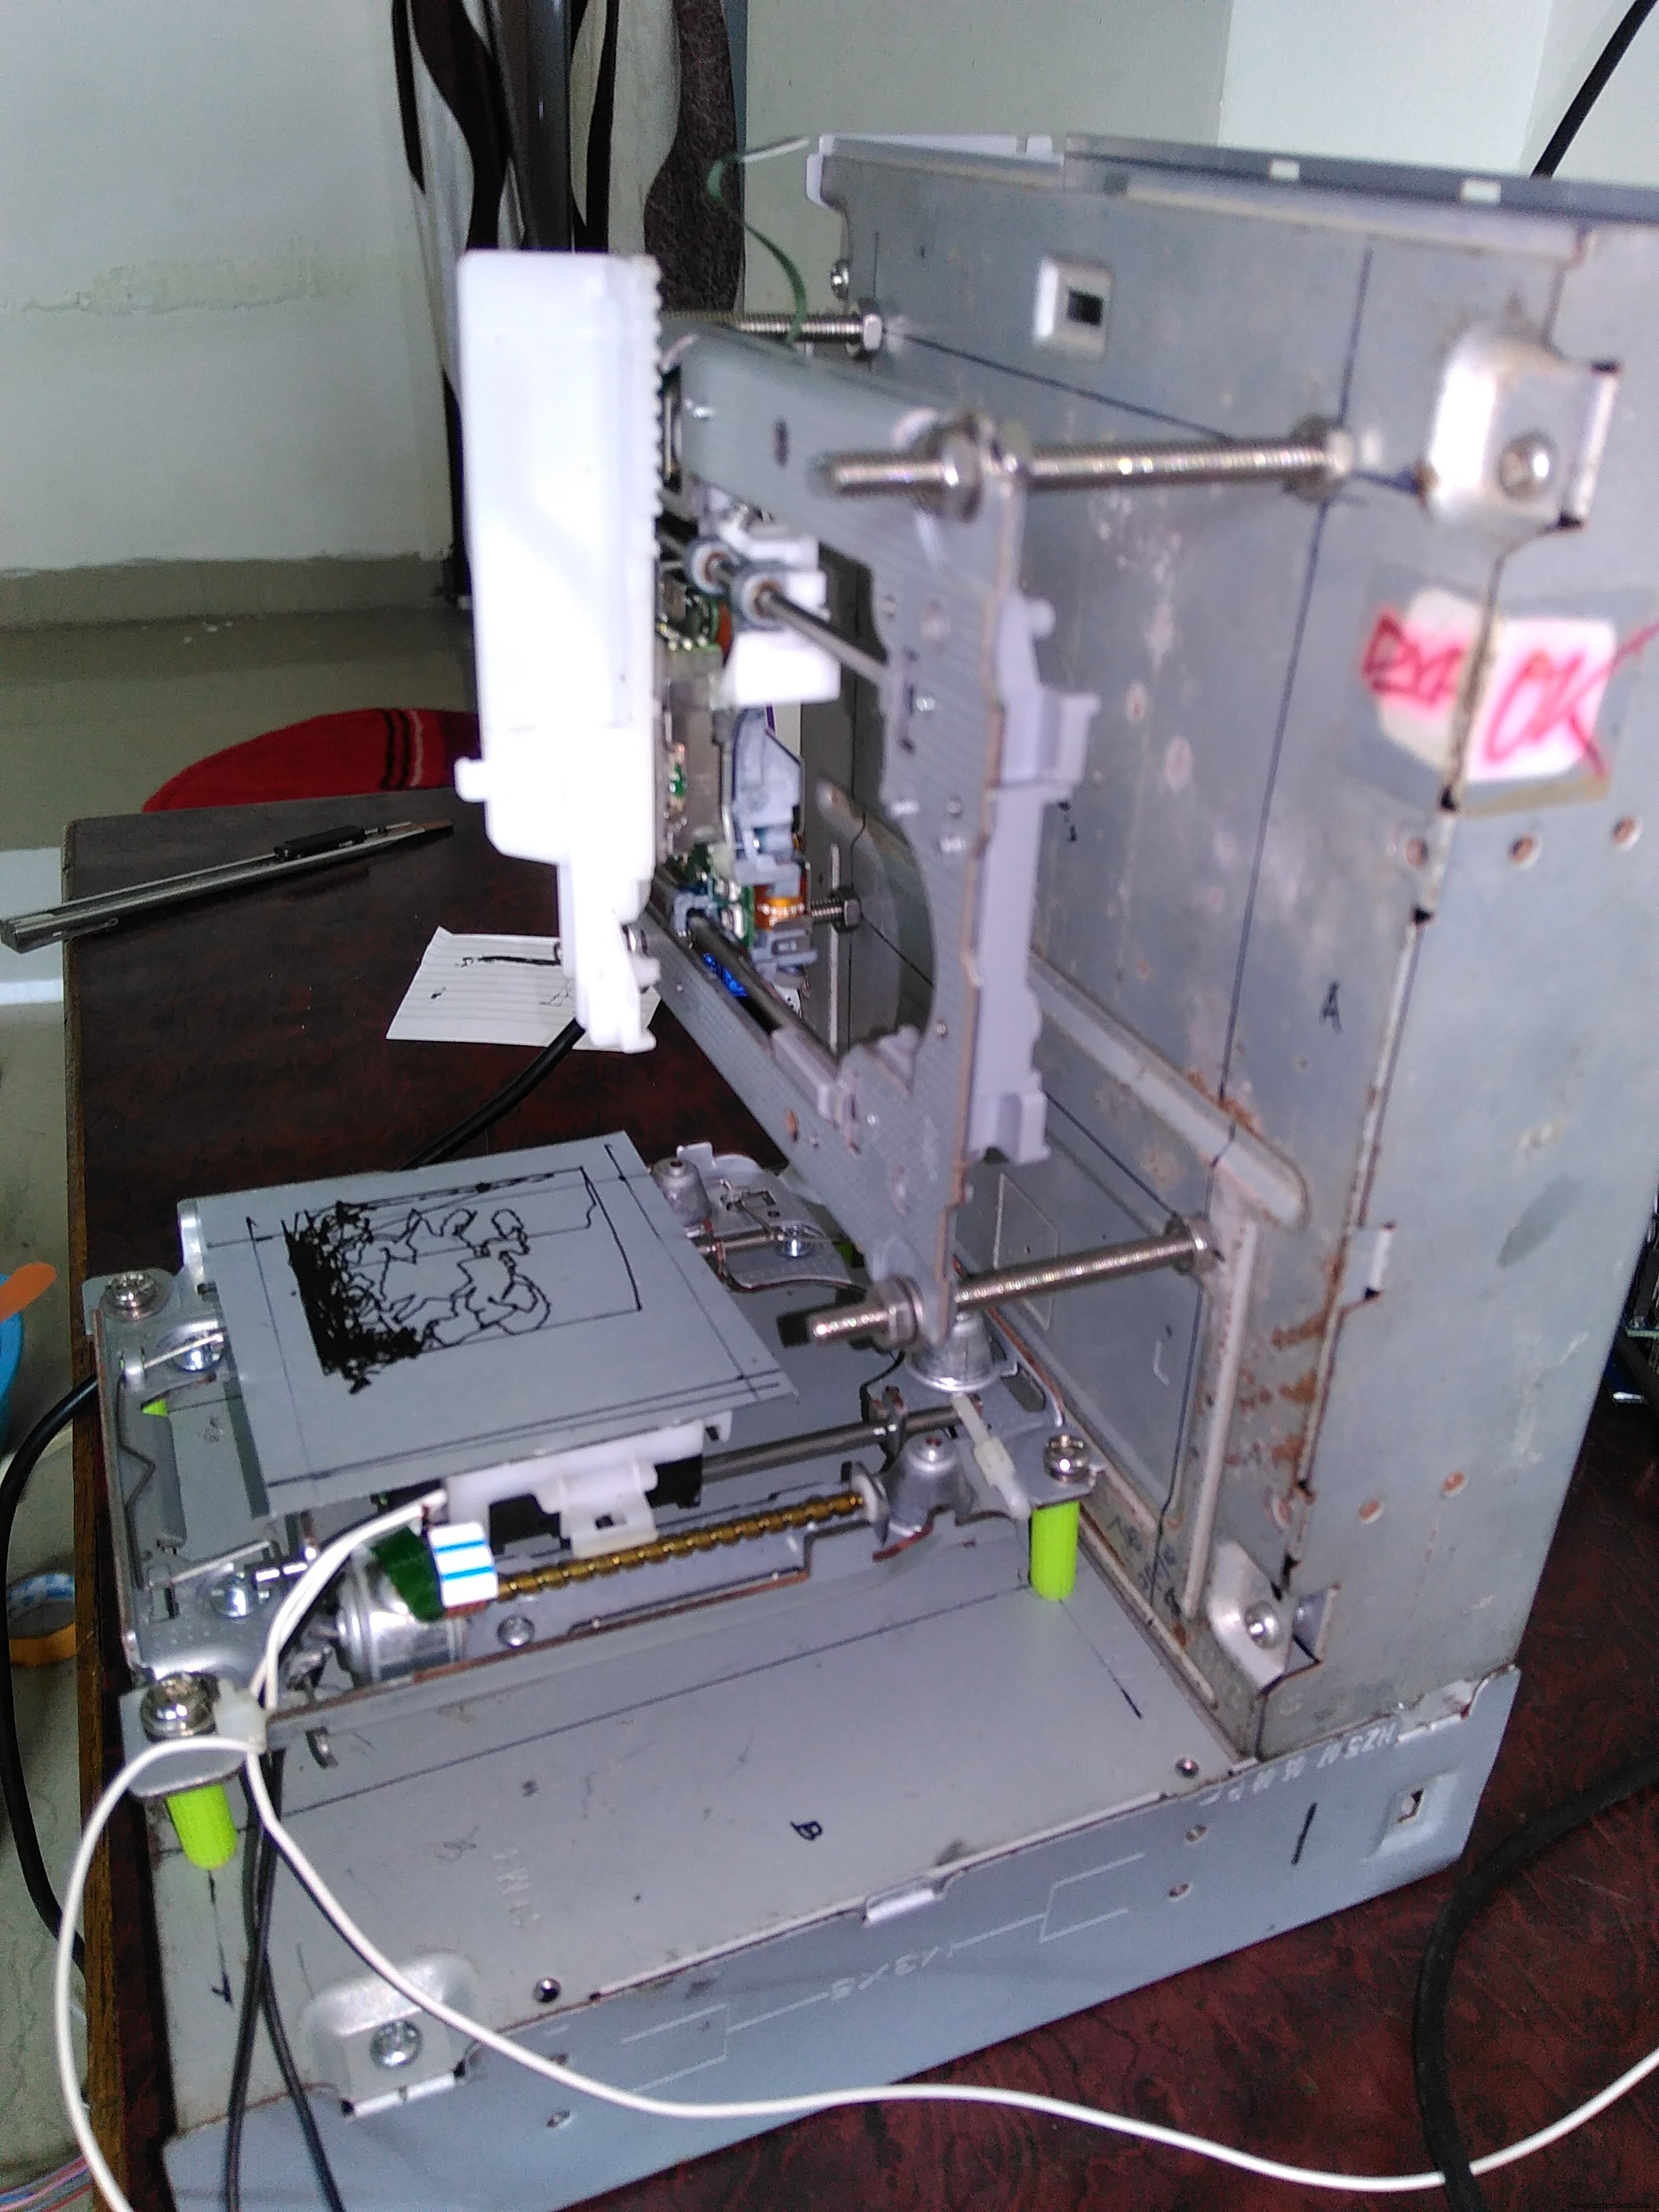
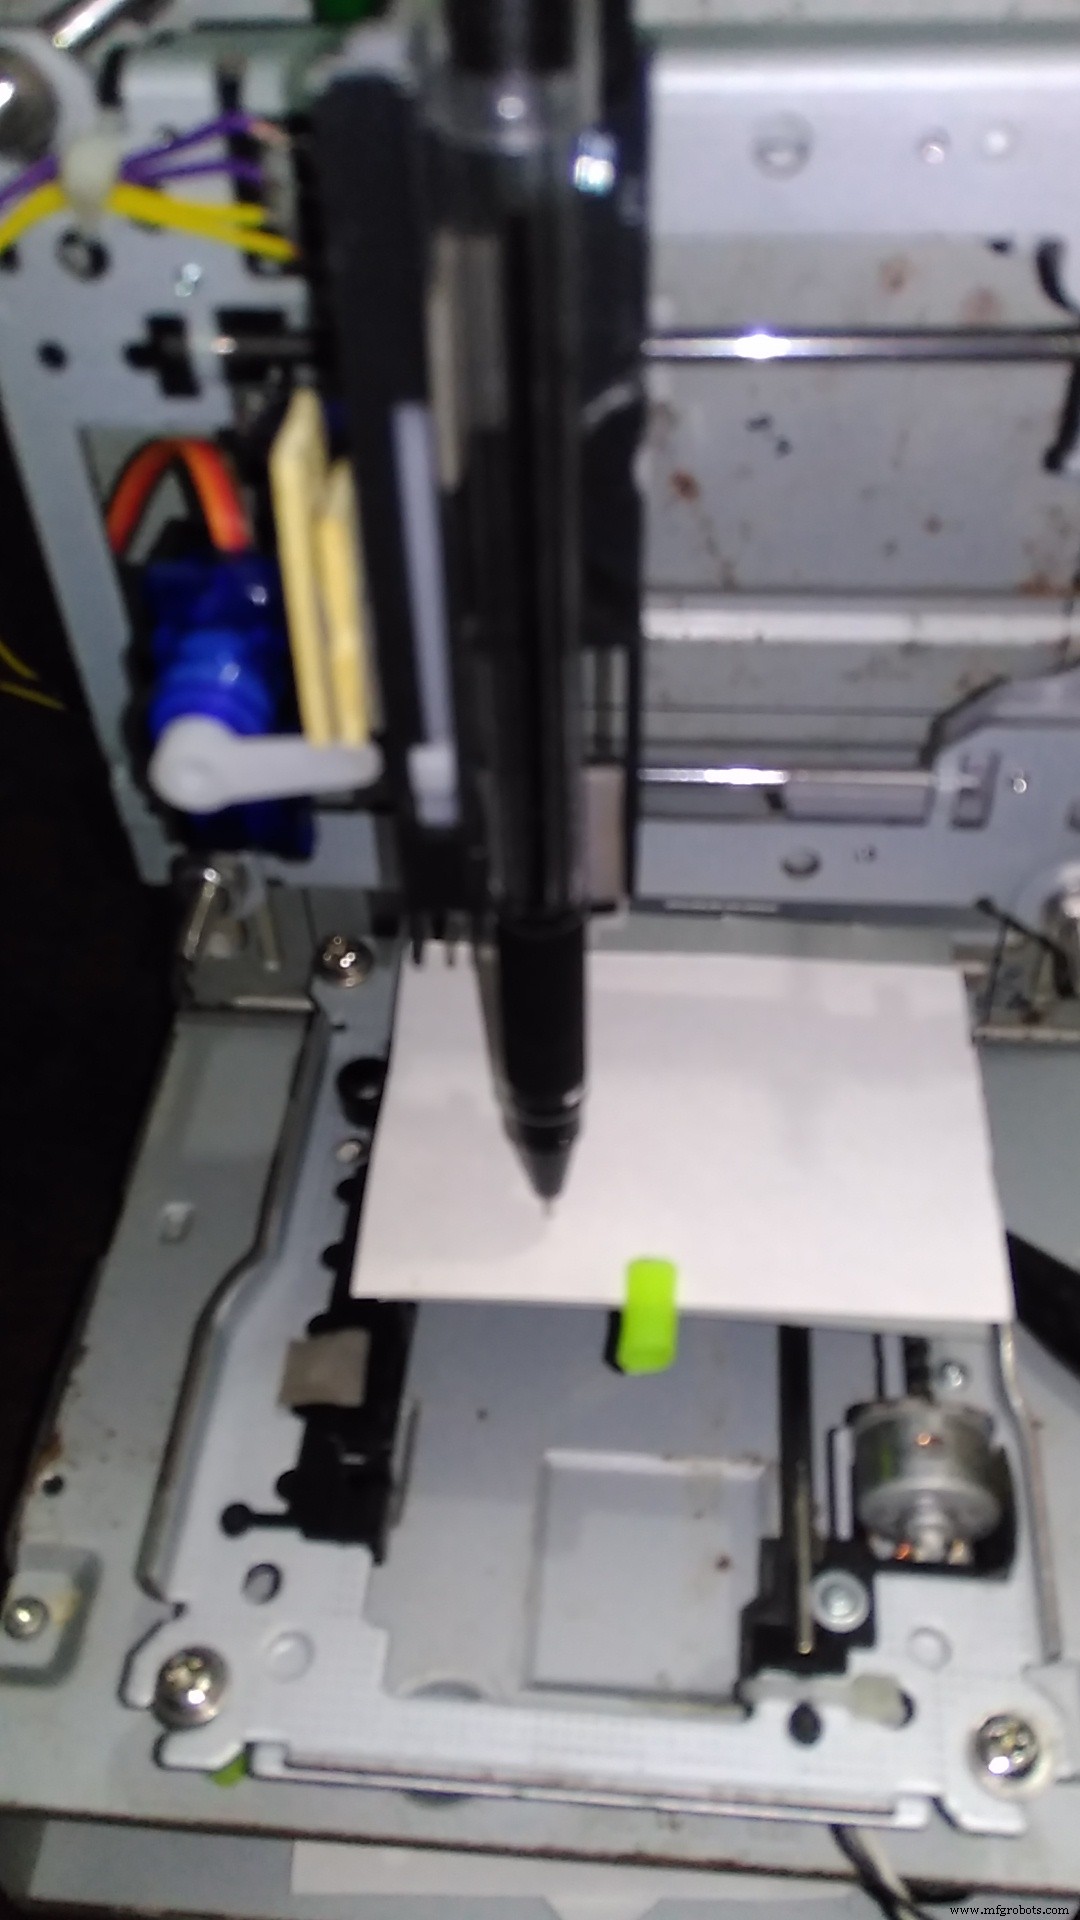
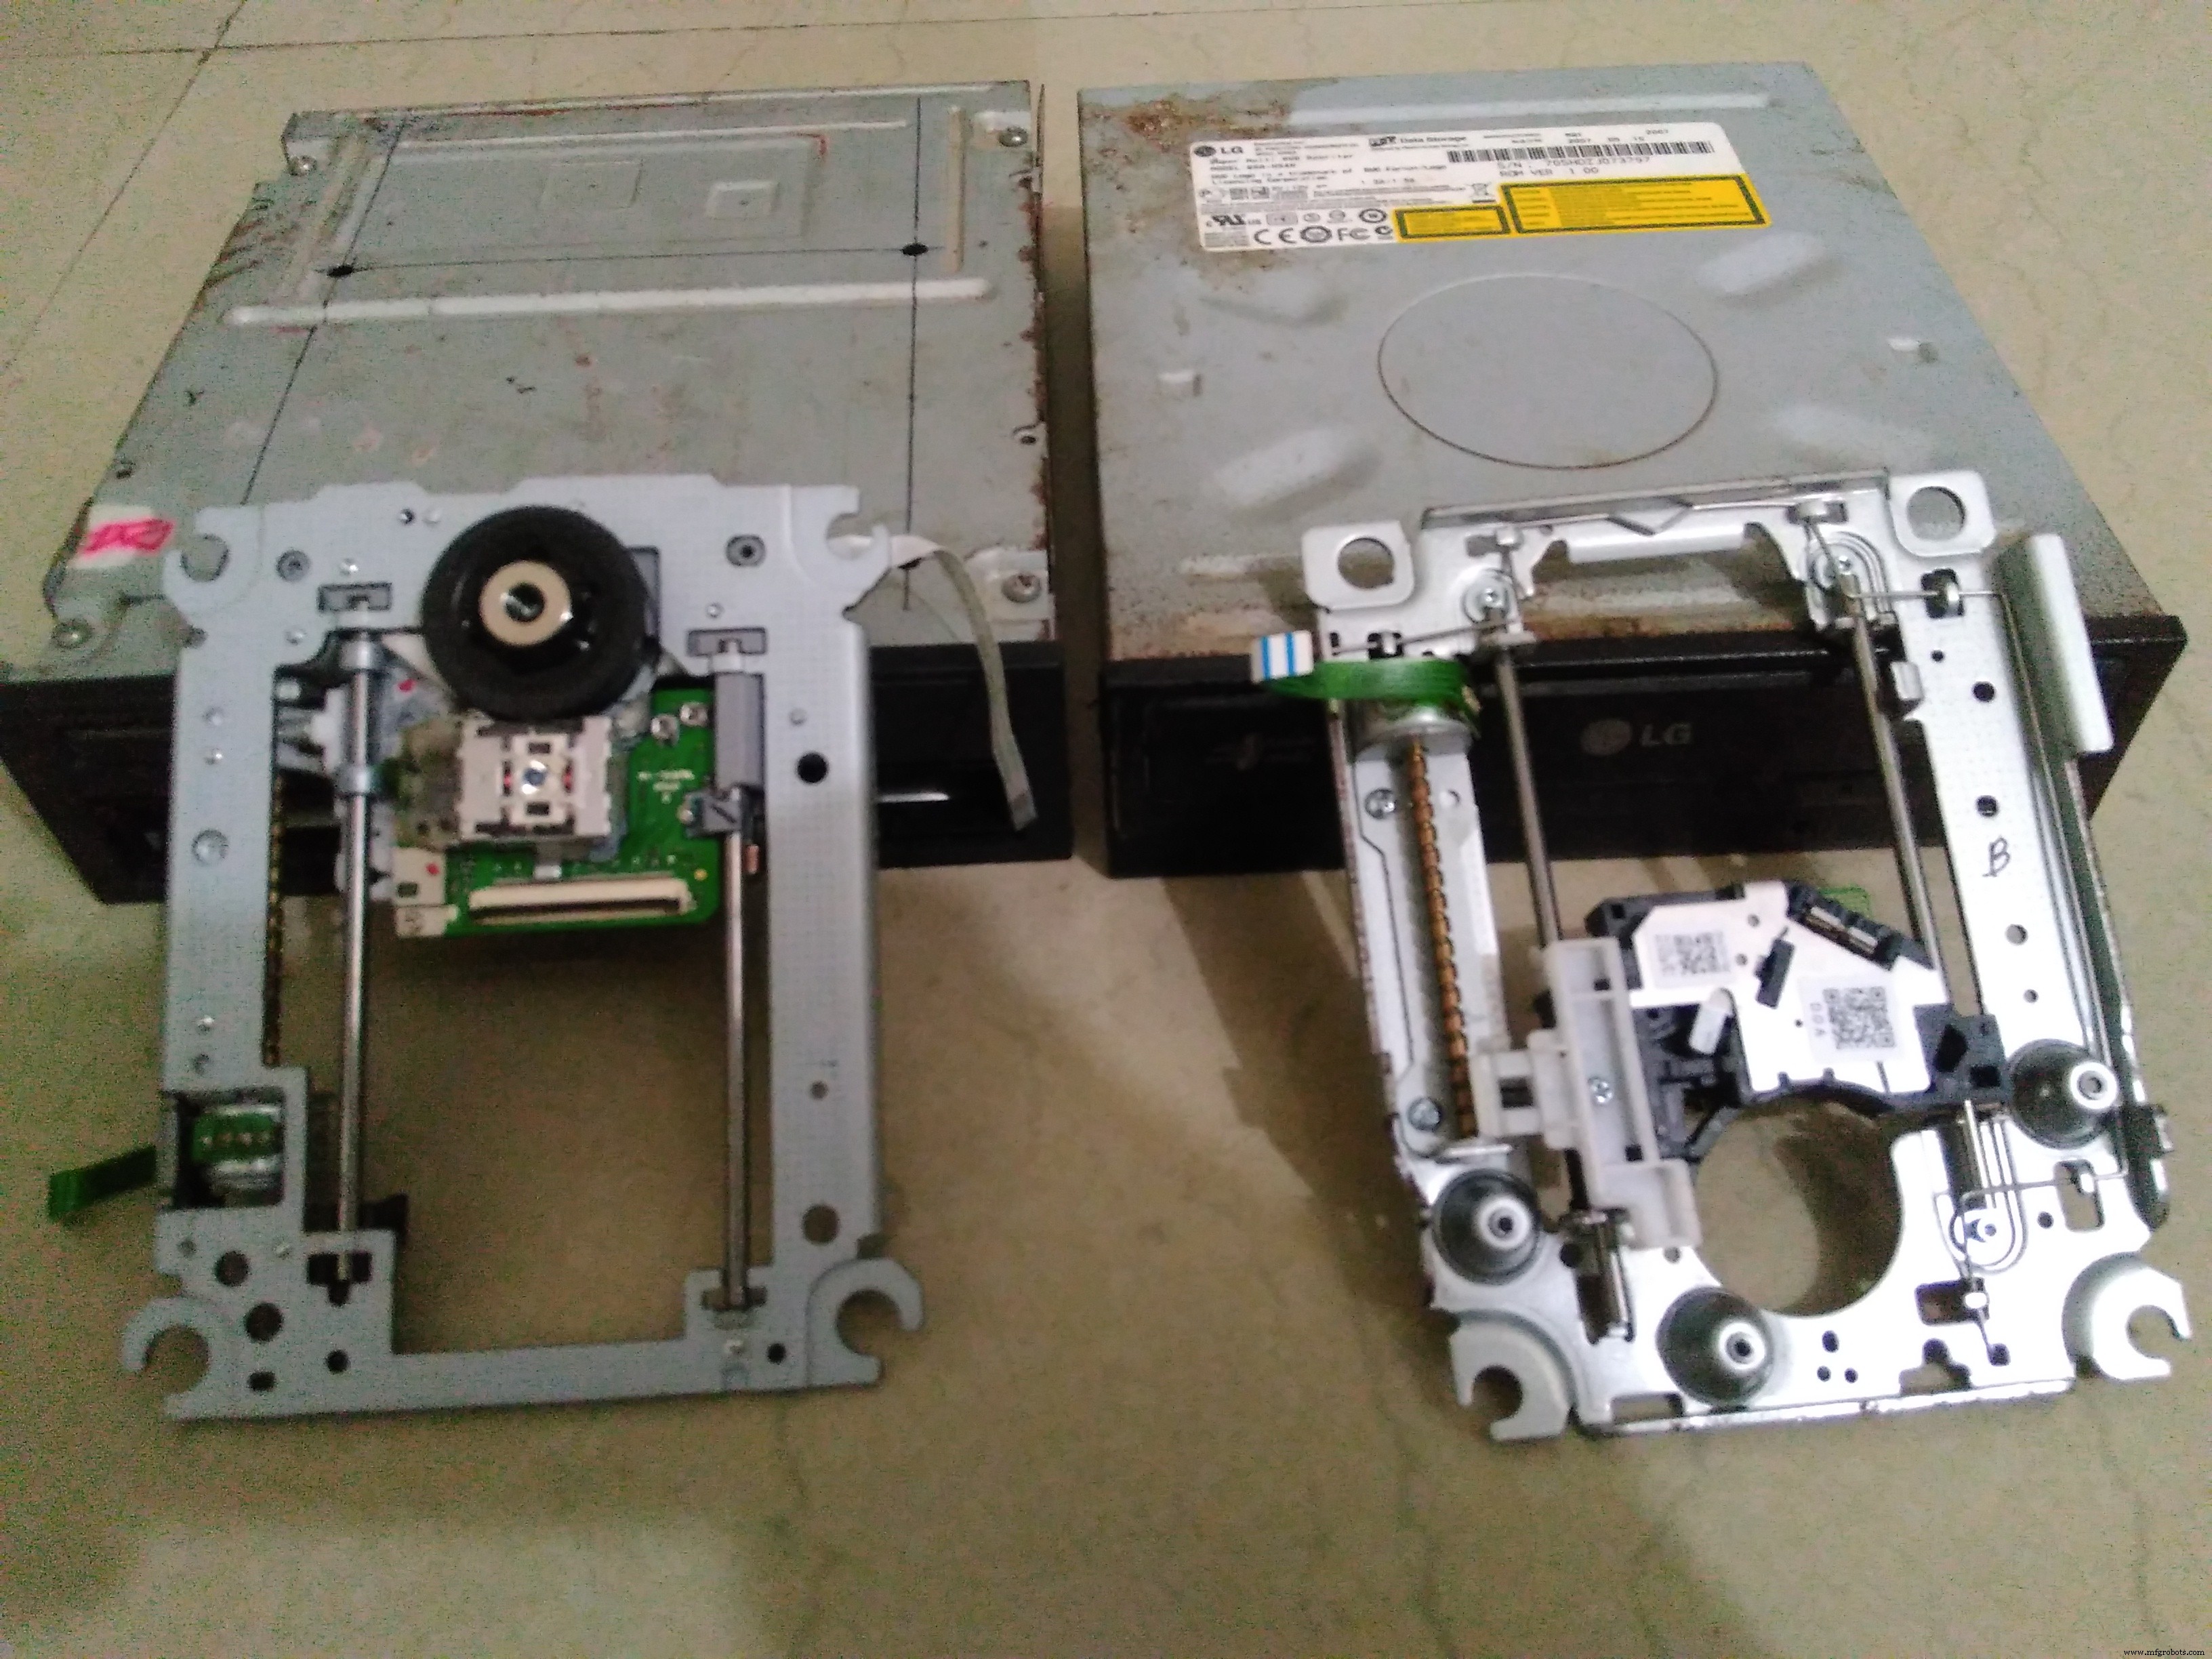
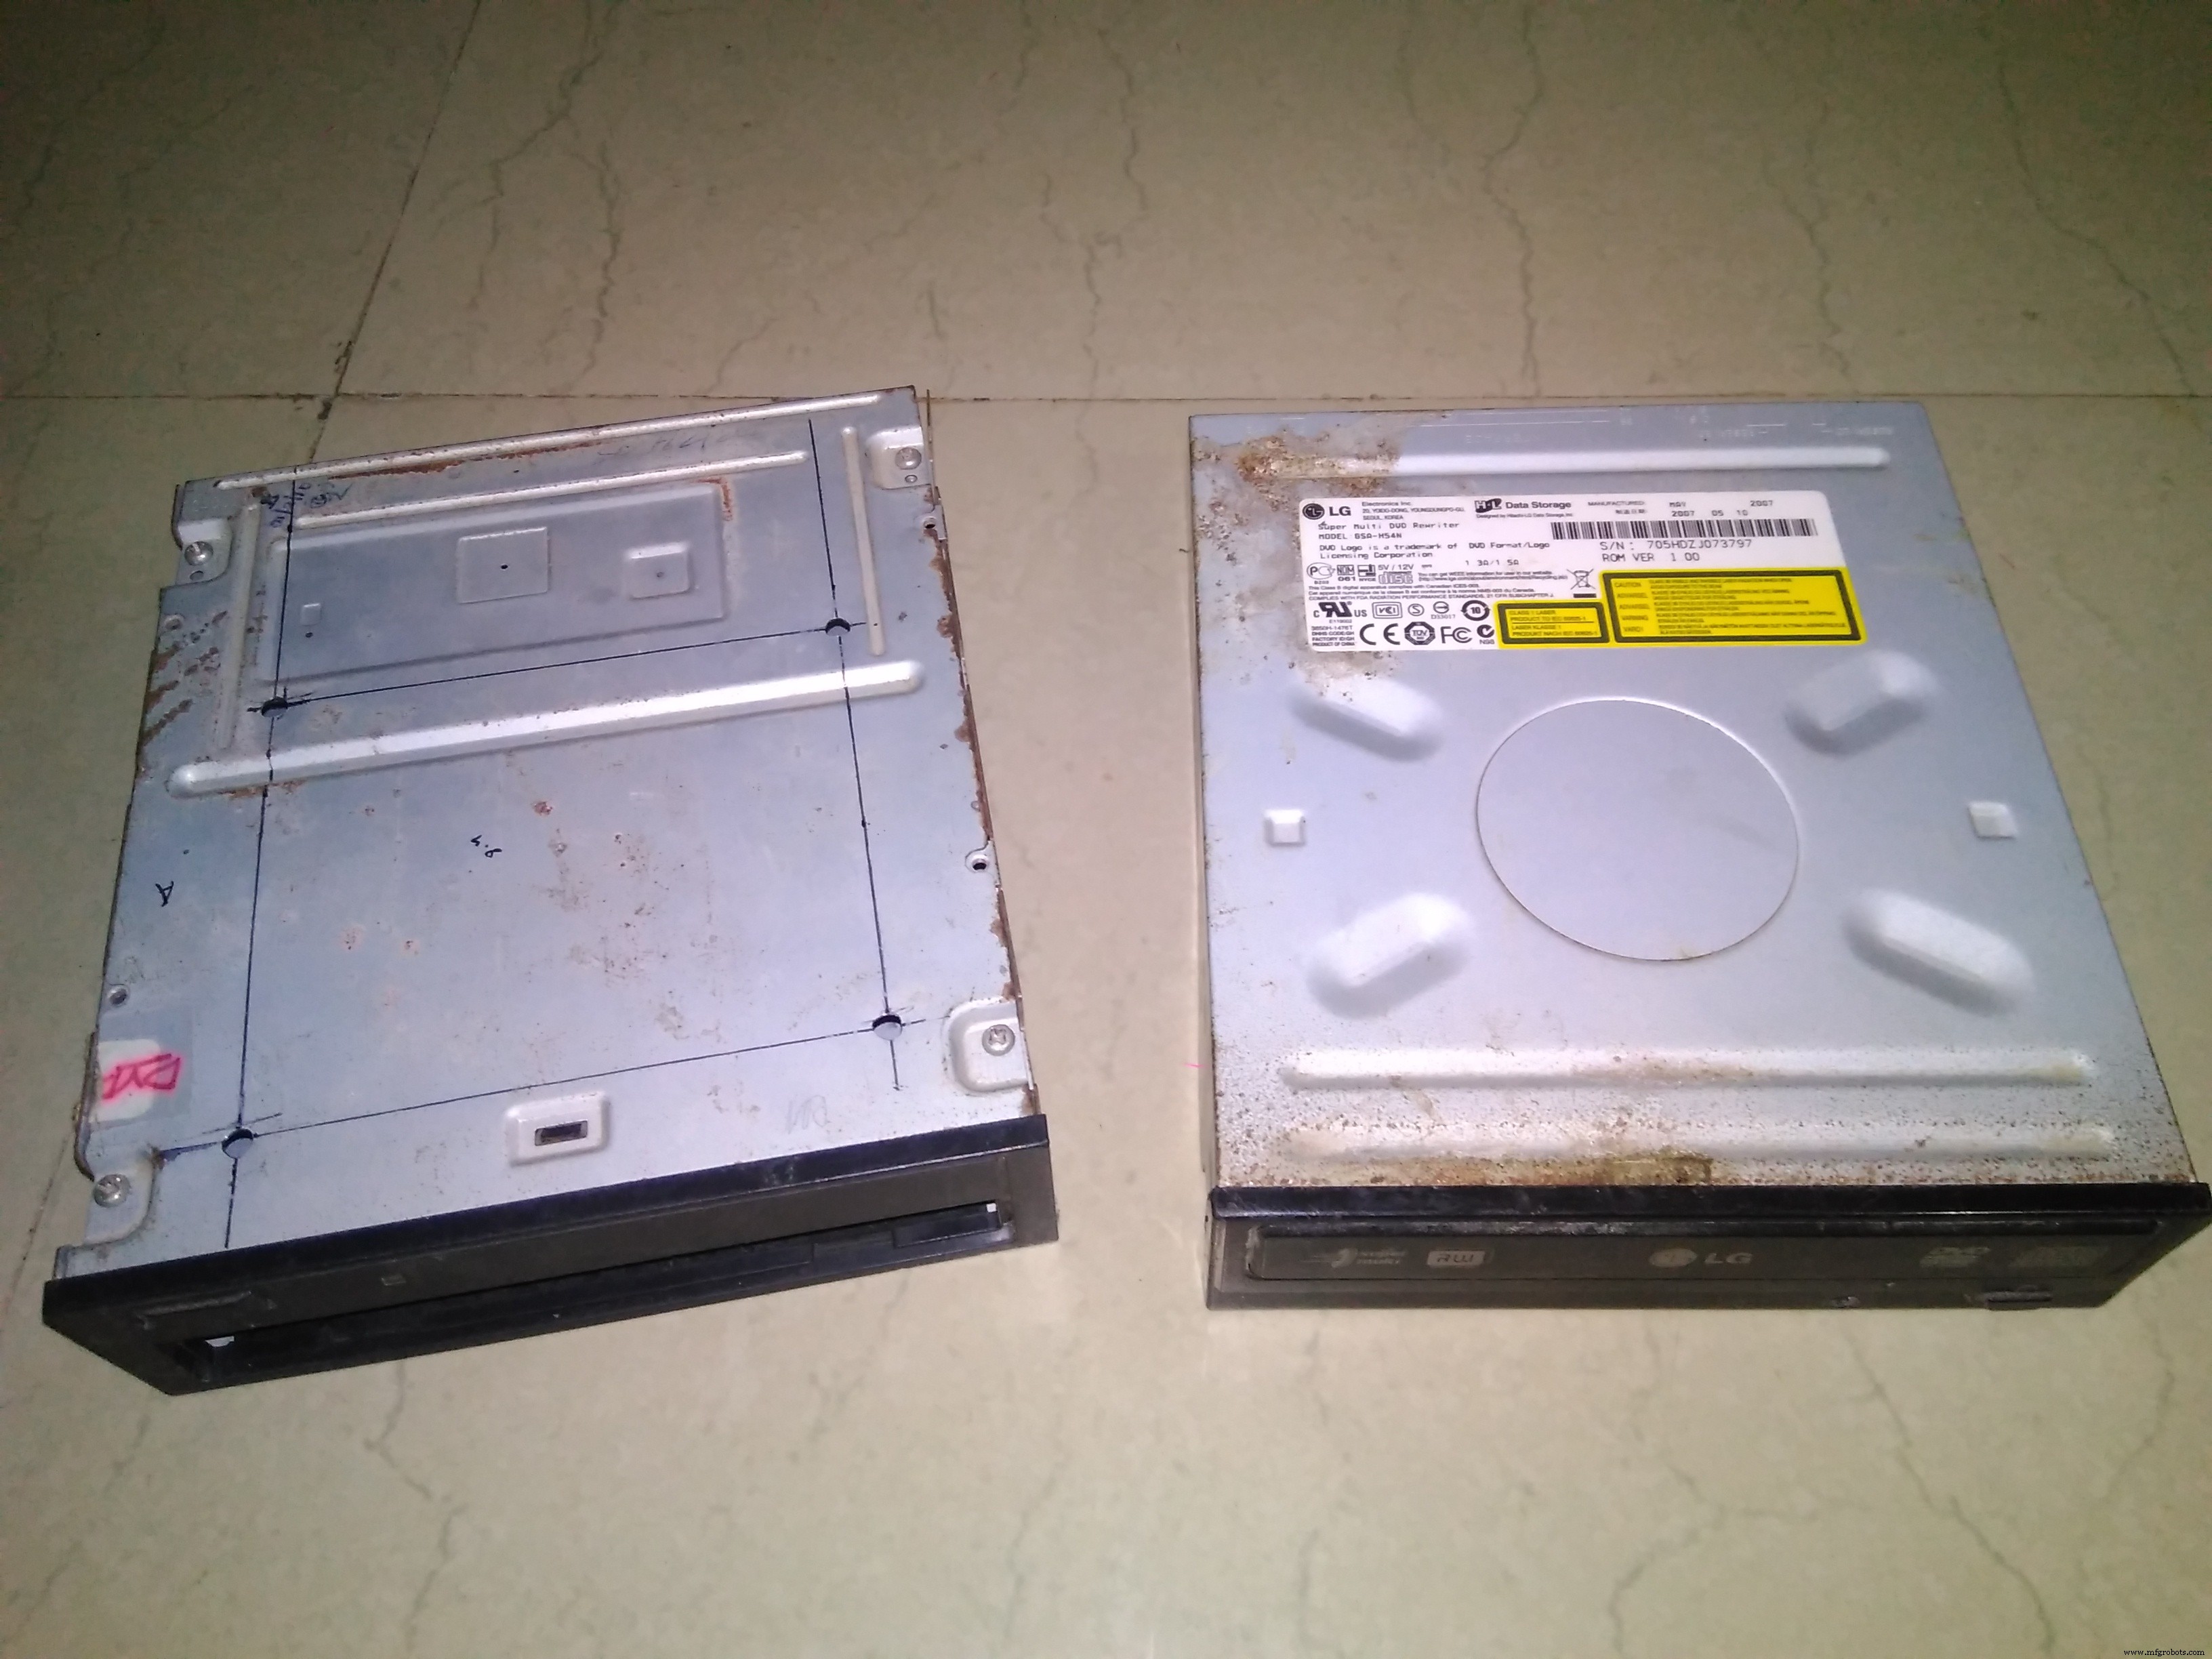
Vídeo da máquina em ação: (link no original)
Código
Código Arduino CNC
#include <Servo.h>
#include <AFMotor.h>
#define LINE_BUFFER_LENGTH 512
char STEP = MICROSTEP;

// Posições servo Up/Down
const int penZUp = 95;
const int penZDown = 83;
const int penServoPin = 10;
const int stepsPerRevolution = 48;

Servo penServo;
AF_Stepper myStepperY(stepsPerRevolution, 1);
AF_Stepper myStepperX(stepsPerRevolution, 2);

struct point { float x, y, z; };
struct point actuatorPos;

float StepInc = 1;
int StepDelay = 0, LineDelay = 0, penDelay = 50;
float StepsPerMillimeterX = 100.0;
float StepsPerMillimeterY = 100.0;
float Xmin = 0, Xmax = 40, Ymin = 0, Ymax = 40, Zmin = 0, Zmax = 1;
float Xpos = Xmin, Ypos = Ymin, Zpos = Zmax;
boolean verbose = false;

void setup() {
  Serial.begin(9600);
  penServo.attach(penServoPin);
  penServo.write(penZUp);
  delay(100);
  myStepperX.setSpeed(600);
  myStepperY.setSpeed(600);
  Serial.println("Mini CNC Plotter alive and kicking!");
  Serial.print("X range: "); Serial.print(Xmin); Serial.print(" to "); Serial.print(Xmax); Serial.println(" mm.");
  Serial.print("Y range: "); Serial.print(Ymin); Serial.print(" to "); Serial.print(Ymax); Serial.println(" mm.");
}

void loop() {
  delay(100);
  char line[LINE_BUFFER_LENGTH], c;
  int lineIndex = 0;
  bool lineIsComment = false, lineSemiColon = false;
  while (1) {
    while (Serial.available() > 0) {
      c = Serial.read();
      if (c == '\n' || c == '\r') {
        if (lineIndex > 0) {
          line[lineIndex] = '\0';
          if (verbose) { Serial.print("Received: "); Serial.println(line); }
          processIncomingLine(line, lineIndex);
          lineIndex = 0;
        } else { /* empty/comment */ }
        lineIsComment = false; lineSemiColon = false;
        Serial.println("ok");
      } else {
        if (lineIsComment || lineSemiColon) {
          if (c == ')') lineIsComment = false;
        } else {
          if (c <= ' ') { /* whitespace */ }
          else if (c == '/') { /* block delete ignore */ }
          else if (c == '(') { lineIsComment = true; }
          else if (c == ';') { lineSemiColon = true; }
          else if (lineIndex >= LINE_BUFFER_LENGTH-1) {
            Serial.println("ERROR - lineBuffer overflow");
            lineIsComment = false; lineSemiColon = false;
          }
          else if (c >= 'a' && c <= 'z') line[lineIndex++] = c - 'a' + 'A';
          else line[lineIndex++] = c;
        }
      }
    }
  }
}

void processIncomingLine(char* line, int charNB) {
  int currentIndex = 0;
  char buffer[64];
  struct point newPos; newPos.x = 0; newPos.y = 0;
  while (currentIndex < charNB) {
    switch (line[currentIndex++]) {
      case 'U': penUp(); break;
      case 'D': penDown(); break;
      case 'G':
        buffer[0] = line[currentIndex++];
        buffer[1] = '\0';
        switch (atoi(buffer)) {
          case 0: case 1: // G0/G1
            char* indexX = strchr(line+currentIndex, 'X');
            char* indexY = strchr(line+currentIndex, 'Y');
            if (indexY == NULL) { newPos.x = atof(indexX+1); newPos.y = actuatorPos.y; }
            else if (indexX == NULL) { newPos.y = atof(indexY+1); newPos.x = actuatorPos.x; }
            else { newPos.y = atof(indexY+1); *indexY = '\0'; newPos.x = atof(indexX+1); }
            drawLine(newPos.x, newPos.y);
            actuatorPos.x = newPos.x; actuatorPos.y = newPos.y;
            break;
        }
        break;
      case 'M':
        buffer[0] = line[currentIndex++];
        buffer[1] = line[currentIndex++];
        buffer[2] = line[currentIndex++];
        buffer[3] = '\0';
        switch (atoi(buffer)) {
          case 300:
            char* indexS = strchr(line+currentIndex, 'S');
            float Spos = atof(indexS+1);
            if (Spos == 30) penDown();
            if (Spos == 50) penUp();
            break;
          case 114: // M114
            Serial.print("Absolute position: X="); Serial.print(actuatorPos.x);
            Serial.print(" Y="); Serial.println(actuatorPos.y);
            break;
          default:
            Serial.print("Command not recognized: M"); Serial.println(buffer);
        }
        break;
    }
  }
}

void drawLine(float x1, float y1) {
  if (verbose) { Serial.print("fx1,fy1: "); Serial.print(x1); Serial.print(","); Serial.print(y1); Serial.println(); }
  if (x1 >= Xmax) x1 = Xmax; if (x1 <= Xmin) x1 = Xmin;
  if (y1 >= Ymax) y1 = Ymax; if (y1 <= Ymin) y1 = Ymin;
  if (verbose) { Serial.print("Xpos,Ypos: "); Serial.print(Xpos); Serial.print(","); Serial.print(Ypos); Serial.println(); }
  if (verbose) { Serial.print("x1,y1: "); Serial.print(x1); Serial.print(","); Serial.print(y1); Serial.println(); }
  x1 = (int)(x1 * StepsPerMillimeterX);
  y1 = (int)(y1 * StepsPerMillimeterY);
  float x0 = Xpos, y0 = Ypos;
  long dx = abs(x1-x0), dy = abs(y1-y0);
  int sx = (x0 < x1) ? StepInc : -StepInc;
  int sy = (y0 < y1) ? StepInc : -StepInc;
  long i, over = 0;
  if (dx > dy) {
    for (i=0; i= dx) { over -= dx; myStepperY.onestep(sy, STEP); }
      delay(StepDelay);
    }
  } else {
    for (i=0; i= dy) { over -= dy; myStepperX.onestep(sx, STEP); }
      delay(StepDelay);
    }
  }
  if (verbose) { Serial.print("dx,dy:"); Serial.print(dx); Serial.print(","); Serial.print(dy); Serial.println(); }
  if (verbose) { Serial.print("Going to ("); Serial.print(x0); Serial.print(","); Serial.print(y0); Serial.println(")"); }
  delay(LineDelay);
  Xpos = x1; Ypos = y1;
}

void penUp() {
  penServo.write(penZUp); delay(penDelay); Zpos = Zmax;
  digitalWrite(15, LOW); digitalWrite(16, HIGH);
  if (verbose) Serial.println("Pen up!");
}

void penDown() {
  penServo.write(penZDown); delay(penDelay); Zpos = Zmin;
  digitalWrite(15, HIGH); digitalWrite(16, LOW);
  if (verbose) Serial.println("Pen down.");
}
Código Processing
import java.awt.event.KeyEvent;
import javax.swing.JOptionPane;
import processing.serial.*;

Serial port = null;
String portname = null; // null = interativo (pressione 'p')
boolean streaming = false;
float speed = 0.001;
String[] gcode;
int i = 0;

void openSerialPort() {
  if (portname == null) return;
  if (port != null) port.stop();
  port = new Serial(this, portname, 9600);
  port.bufferUntil('\n');
}

void selectSerialPort() {
  String result = (String) JOptionPane.showInputDialog(frame,
    "Select the serial port that corresponds to your Arduino board.",
    "Select serial port", JOptionPane.QUESTION_MESSAGE, null, Serial.list(), 0);
  if (result != null) { portname = result; openSerialPort(); }
}

void setup() { size(500, 250); openSerialPort(); }

void draw() {
  background(0); fill(255);
  int y = 24, dy = 12;
  text("INSTRUCTIONS", 12, y); y += dy;
  text("p: select serial port", 12, y); y += dy;
  text("1: speed 0.001 in (1 mil) per jog", 12, y); y += dy;
  text("2: speed 0.010 in (10 mil) per jog", 12, y); y += dy;
  text("3: speed 0.100 in (100 mil) per jog", 12, y); y += dy;
  text("arrow keys: jog in x-y plane", 12, y); y += dy;
  text("page up/down: jog in z axis", 12, y); y += dy;
  text("$: display grbl settings", 12, y); y += dy;
  text("h: go home", 12, y); y += dy;
  text("0: zero machine (set home)", 12, y); y += dy;
  text("g: stream g-code file", 12, y); y += dy;
  text("x: stop streaming (not immediate)", 12, y); y += dy;
  y = height - dy;
  text("current jog speed: " + speed + " inches per step", 12, y); y -= dy;
  text("current serial port: " + portname, 12, y); y -= dy;
}

void keyPressed() {
  if (key == '1') speed = 0.001;
  if (key == '2') speed = 0.01;
  if (key == '3') speed = 0.1;
  if (!streaming) {
    if (keyCode == LEFT)  port.write("G91\nG20\nG00 X-" + speed + " Y0.000 Z0.000\n");
    if (keyCode == RIGHT) port.write("G91\nG20\nG00 X" + speed + " Y0.000 Z0.000\n");
    if (keyCode == UP)    port.write("G91\nG20\nG00 X0.000 Y" + speed + " Z0.000\n");
    if (keyCode == DOWN)  port.write("G91\nG20\nG00 X0.000 Y-" + speed + " Z0.000\n");
    if (keyCode == KeyEvent.VK_PAGE_UP)   port.write("G91\nG20\nG00 X0.000 Y0.000 Z" + speed + "\n");
    if (keyCode == KeyEvent.VK_PAGE_DOWN) port.write("G91\nG20\nG00 X0.000 Y0.000 Z-" + speed + "\n");
    if (key == 'h') port.write("G90\nG20\nG00 X0.000 Y0.000 Z0.000\n");
    if (key == 'v') port.write("$0=75\n$1=74\n$2=75\n");
    if (key == 's') port.write("$3=10\n");
    if (key == 'e') port.write("$16=1\n");
    if (key == 'd') port.write("$16=0\n");
    if (key == '0') openSerialPort();
    if (key == 'p') selectSerialPort();
    if (key == '$') port.write("$$\n");
  }
  if (!streaming && key == 'g') {
    gcode = null; i = 0;
    println("Loading file...");
    selectInput("Select a file to process:", "fileSelected", null);
  }
  if (key == 'x') streaming = false;
}

void fileSelected(File selection) {
  if (selection == null) println("Window closed or cancelled.");
  else {
    println("User selected " + selection.getAbsolutePath());
    gcode = loadStrings(selection.getAbsolutePath());
    if (gcode == null) return;
    streaming = true; stream();
  }
}

void stream() {
  if (!streaming) return;
  while (true) {
    if (i == gcode.length) { streaming = false; return; }
    if (gcode[i].trim().length() == 0) i++; else break;
  }
  println(gcode[i]);
  port.write(gcode[i] + '\n'); i++;
}

void serialEvent(Serial p) {
  String s = p.readStringUntil('\n');
  println(s.trim());
  if (s.trim().startsWith("ok")) stream();
  if (s.trim().startsWith("error")) stream();
}
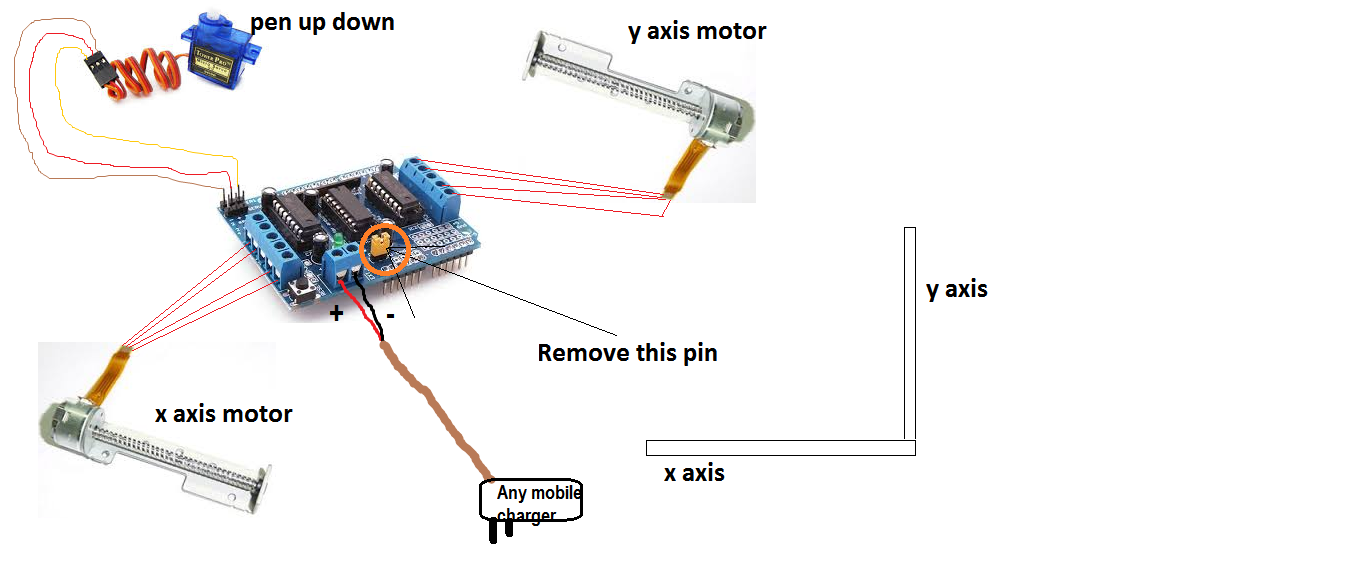
Esquemático
Conecte todos os componentes conforme a figura:
Processo de manufatura
- Construa Sua Própria Máquina de Escrever Deveres de Casa (Plotter de Caneta) em Casa
- Crie um Sistema Ambilight Impressionante para Monitor com Arduino
- Robô de Detecção Humana Baseado em Arduino Uno: Integração de Sensores Passo a Passo
- Veículo Remoto Controlado por Android com Raspberry Pi e Motor Shield
- Crie um Botão de Teclado "Socável" Personalizado com Arduino: Guia Passo a Passo
- Medir a Massa da Terra com Arduino: Guia DIY Passo a Passo
- Interface Web em PHP para Controlar Arduino Uno via Ethernet Shield
- Criar Tons Musicais com Arduino: Um Guia Passo a Passo
- Porta Automática com Arduino e Sensor Ultrassônico HC-SR04
- Construa uma Bússola Digital em Tempo Real com Arduino e Processing